Actuation travel
Compression from first contact until the sensing signal changes. This is only the first part of the contact event.
Choose a contact-sensing profile for the edge of a moving door, mobile vehicle or machine guard. Compare seven main profiles and 37 extension profiles, then match the mounting, electrical configuration and stopping allowance to your application.
A pressure-sensitive safety edge is a contact-sensing device, not a non-contact distance sensor. When pressure changes the sensing state, the compatible controller and final stopping elements must bring hazardous motion to the required safe condition.
The selected profile is compressed in its intended sensing direction.
The matched input circuit evaluates the state and required diagnostics.
The stop or safe reversing function acts through the final elements.
Stopping travel and remaining compression are checked on the machine.
Compression from first contact until the sensing signal changes. This is only the first part of the contact event.
Additional compression after actuation. Select and validate it against motion after detection, tolerances, temperature and elastic recovery.
| Selection point | JH-PSE | DDB / DDBT |
|---|---|---|
| Product scope | 7 main profiles and 37 extension profiles | Custom range: 5 standard and 6 adhesive sections |
| Listed length | Main: 30-300 cm; extension: 20-300 cm | 200-3000 mm; custom options |
| Mounting | Profile-matched bases and confirmed section drawings | DDB standard mounting / DDBT adhesive mounting |
| Electrical selection | R / K; main and extension cable data differ | 2K / 4K / 2R; custom interface defined by order |
| Best starting point | Compare published main-range dynamics or extension profile geometry | Start with the machine contour, mounting face and custom interface |
Need the other range? Explore DDB / DDBT Safety Edges. A similar outside shape does not establish identical actuation, wiring or stopping performance.
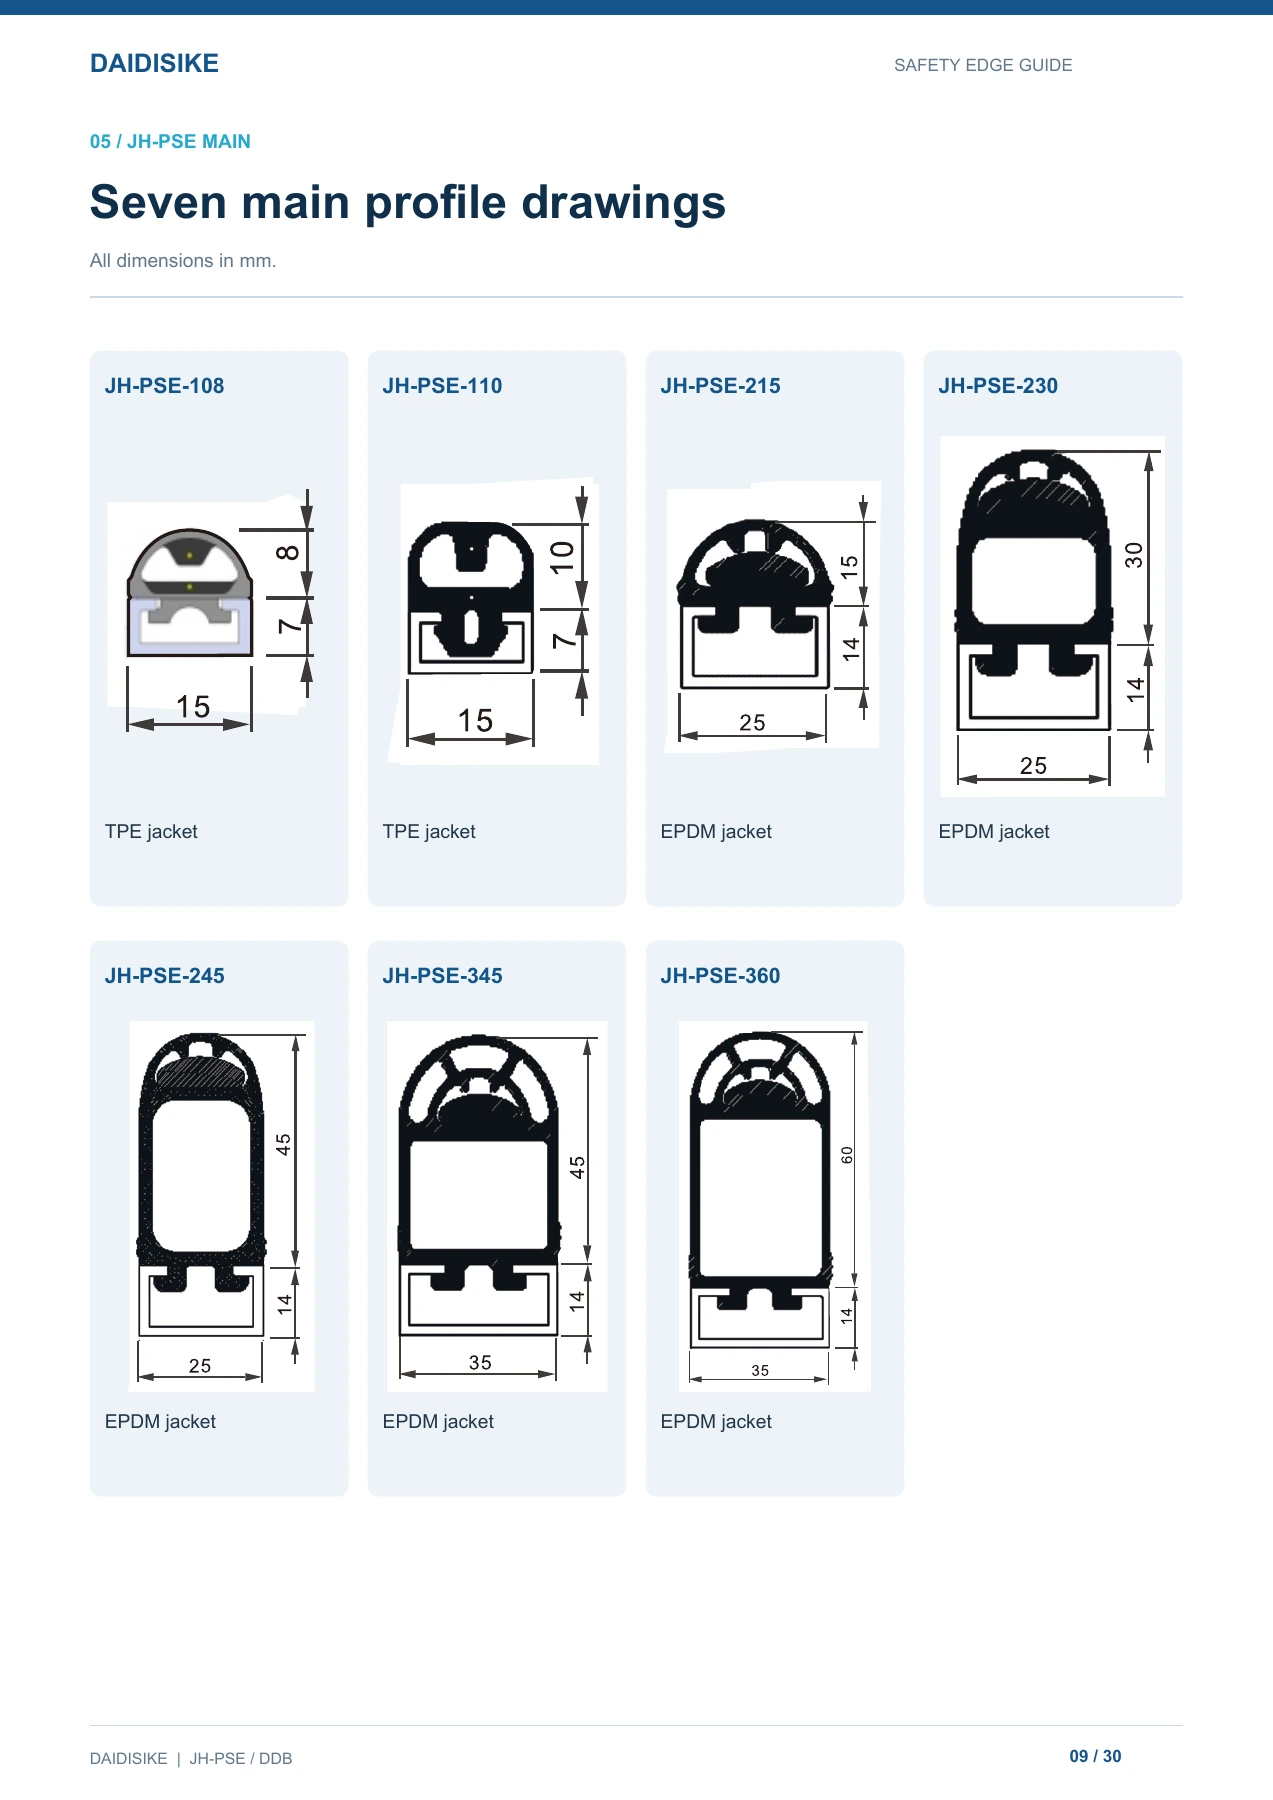
Start with the available mounting width and the compression your application needs. The small 108 / 110 sections suit compact installations; the 25 mm and 35 mm base-width families provide different rubber heights and published actuation values. An application example is a selection starting point, not a machine approval.
| Model | Base width | Rubber height | Base height | Actuation travel | Actuation force | Listed overtravel | Material | Application references |
|---|---|---|---|---|---|---|---|---|
| JH-PSE-108 | 15 | 8 | 7 | <2 | ≤25 | 0 | TPE | Small AGVs |
| JH-PSE-110 | 15 | 10 | 7 | <2 | ≤25 | 0 | TPE | Small AGVs, garage doors, industrial equipment |
| JH-PSE-215 | 25 | 15 | 14 | <3 | ≤25 | 0 | EPDM | AGVs, powered doors, industrial applications |
| JH-PSE-230 | 25 | 30 | 14 | <3 | ≤25 | <19 | EPDM | AGVs, powered doors, industrial applications |
| JH-PSE-245 | 25 | 45 | 14 | <3 | ≤25 | <30 | EPDM | AGVs, powered doors, industrial applications |
| JH-PSE-345 | 35 | 45 | 14 | <5 | ≤100 | <30 | EPDM | Large AGVs, heavy doors, robot perimeters |
| JH-PSE-360 | 35 | 60 | 14 | <5 | ≤100 | <45 | EPDM | Large AGVs, heavy doors, robot perimeters |
The guide lists 0 overtravel for 108, 110 and 215. Values such as <19, <30 and <45 mm are published less-than figures, not guaranteed minimum usable compression or a permitted machine stopping distance. Obtain the selected profile's applicable force/travel information and validate the actual stopping reserve. Rubber height and base height are separate drawing dimensions, not a confirmed assembled overall height.
| Item | Listed data |
|---|---|
| Sensing principle | Pressure sensing |
| Actuation angle | <90° |
| Response time | 13 ms |
| Mechanical life | >3,000,000 operations |
| Ambient temperature | -20 to +55°C |
| Ingress protection | IP65 |
| Jacket material | 108 / 110: TPE; 215 / 230 / 245 / 345 / 360: EPDM |
| Length | 30-300 cm; custom lengths |
The 13 ms figure is a sensor response value, not the full machine stopping time. Do not transfer these main-range values to profiles 01-37 or to DDB/DDBT.
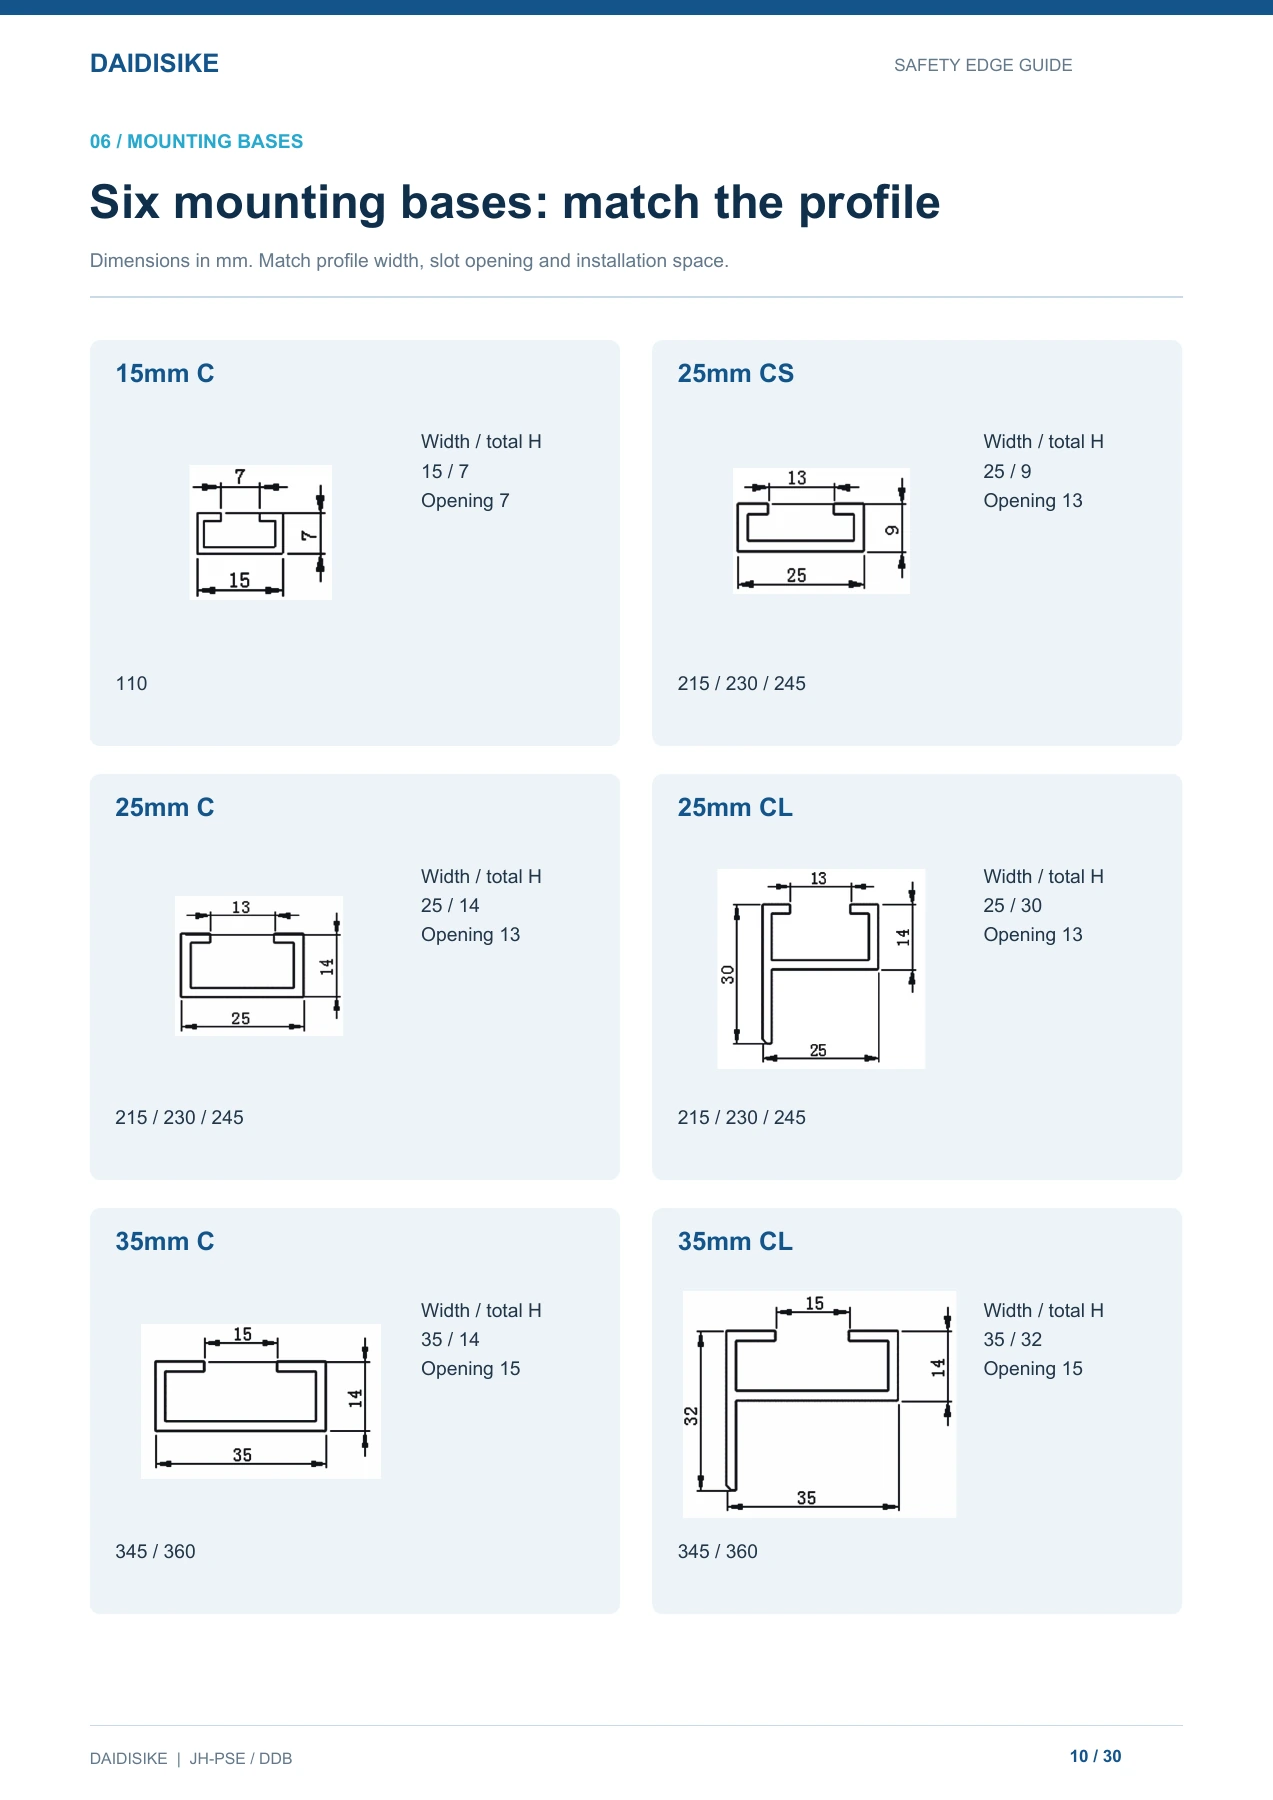
Slot opening, base height, fastener clearance and the rubber retention shape all matter. A tall CL base changes the installation envelope; do not reuse the main-profile base-height figure for every mounting option.
| Base | Width | Total base height | Opening | Listed profiles |
|---|---|---|---|---|
| 15 mm C | 15 | 7 | 7 | 110 |
| 25 mm CS | 25 | 9 | 13 | 215 / 230 / 245 |
| 25 mm C | 25 | 14 | 13 | 215 / 230 / 245 |
| 25 mm CL | 25 | 30 | 13 | 215 / 230 / 245 |
| 35 mm C | 35 | 14 | 15 | 345 / 360 |
| 35 mm CL | 35 | 32 | 15 | 345 / 360 |
The 15 mm C base is explicitly listed for profile 110. The guide does not establish compatibility with 108 merely because both are 15 mm wide. Confirm the complete section/base drawing for your order.
Use a flat, burr-free mounting surface. Fasteners must not intrude into the sensing cavity, press continuously on the rubber, or introduce twist. Confirm end sealing and cable strain relief before commissioning.
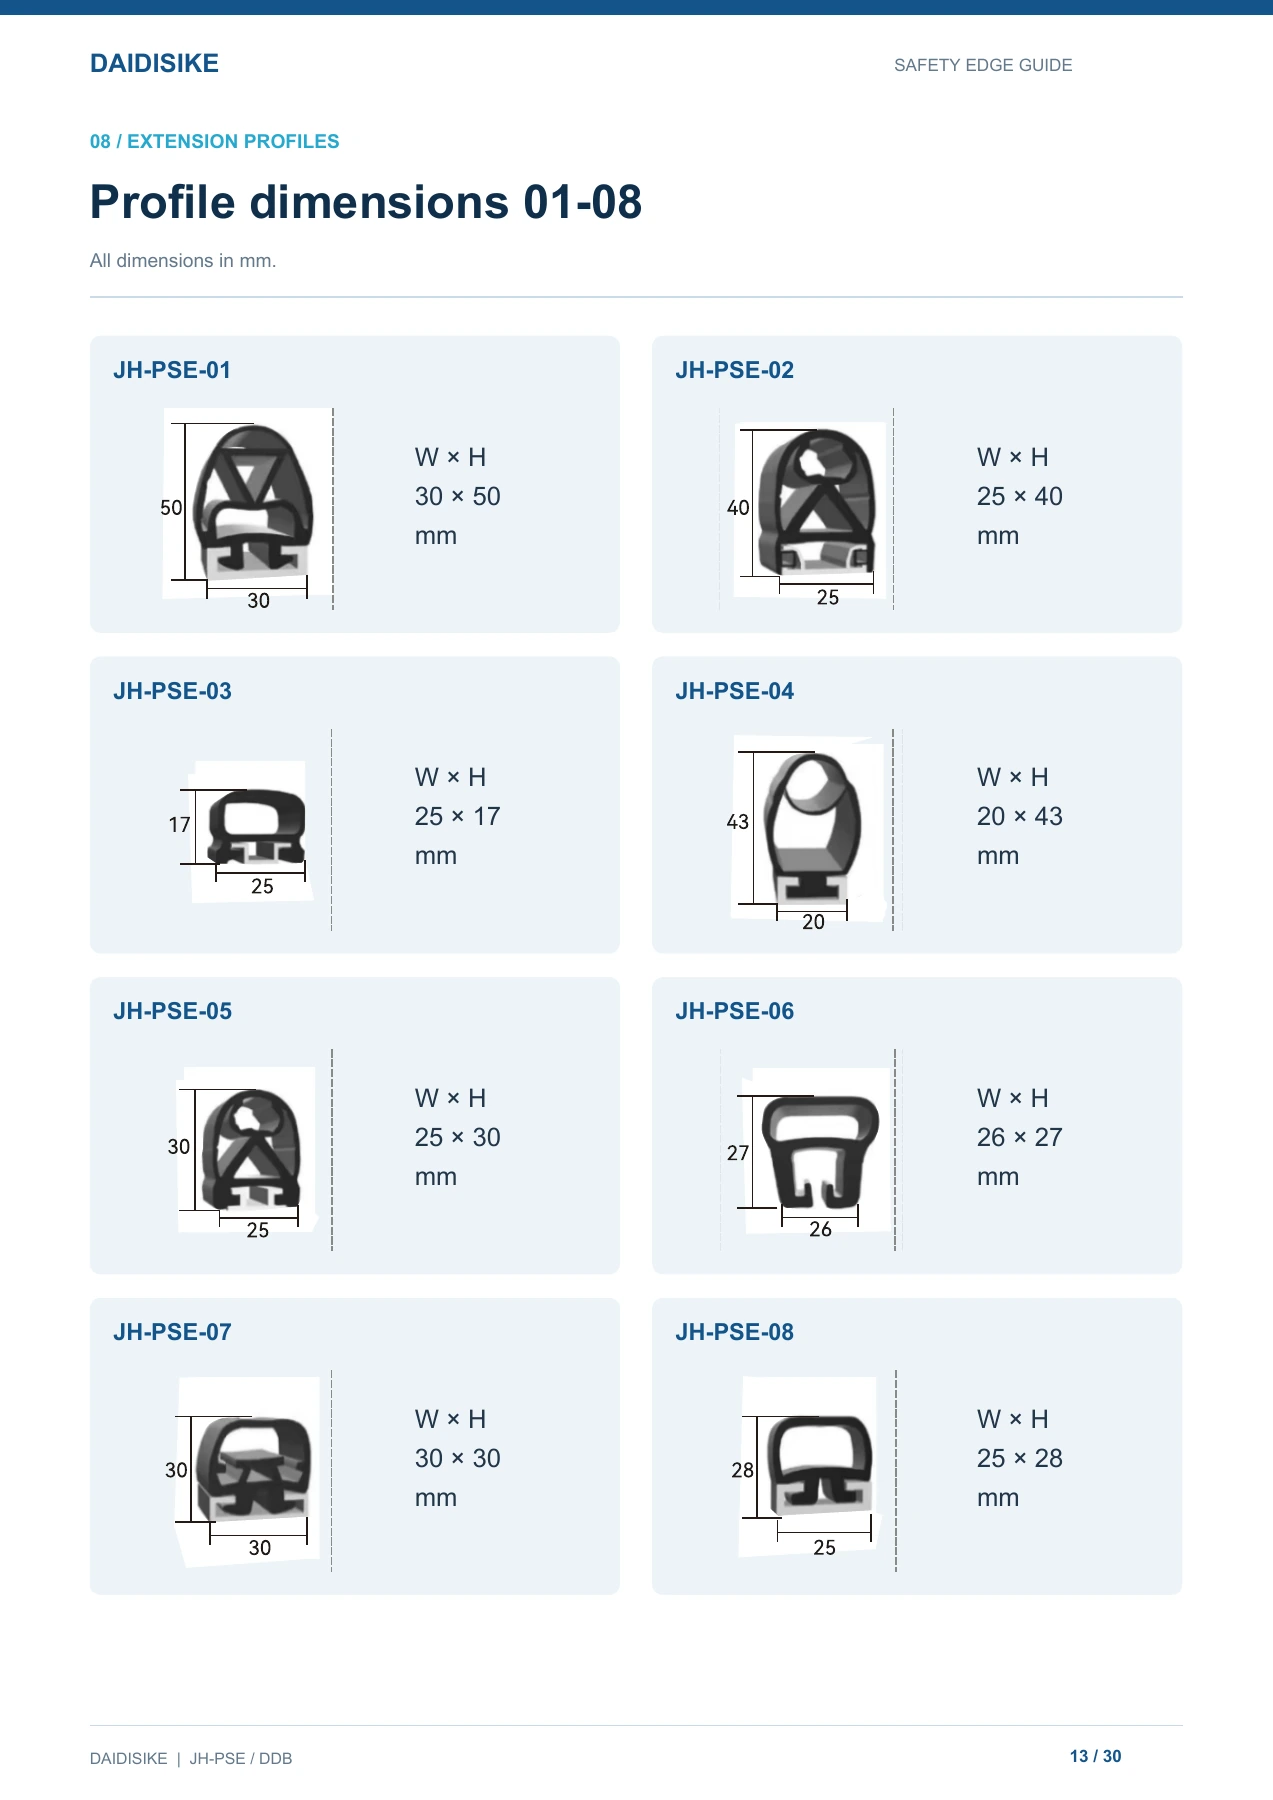
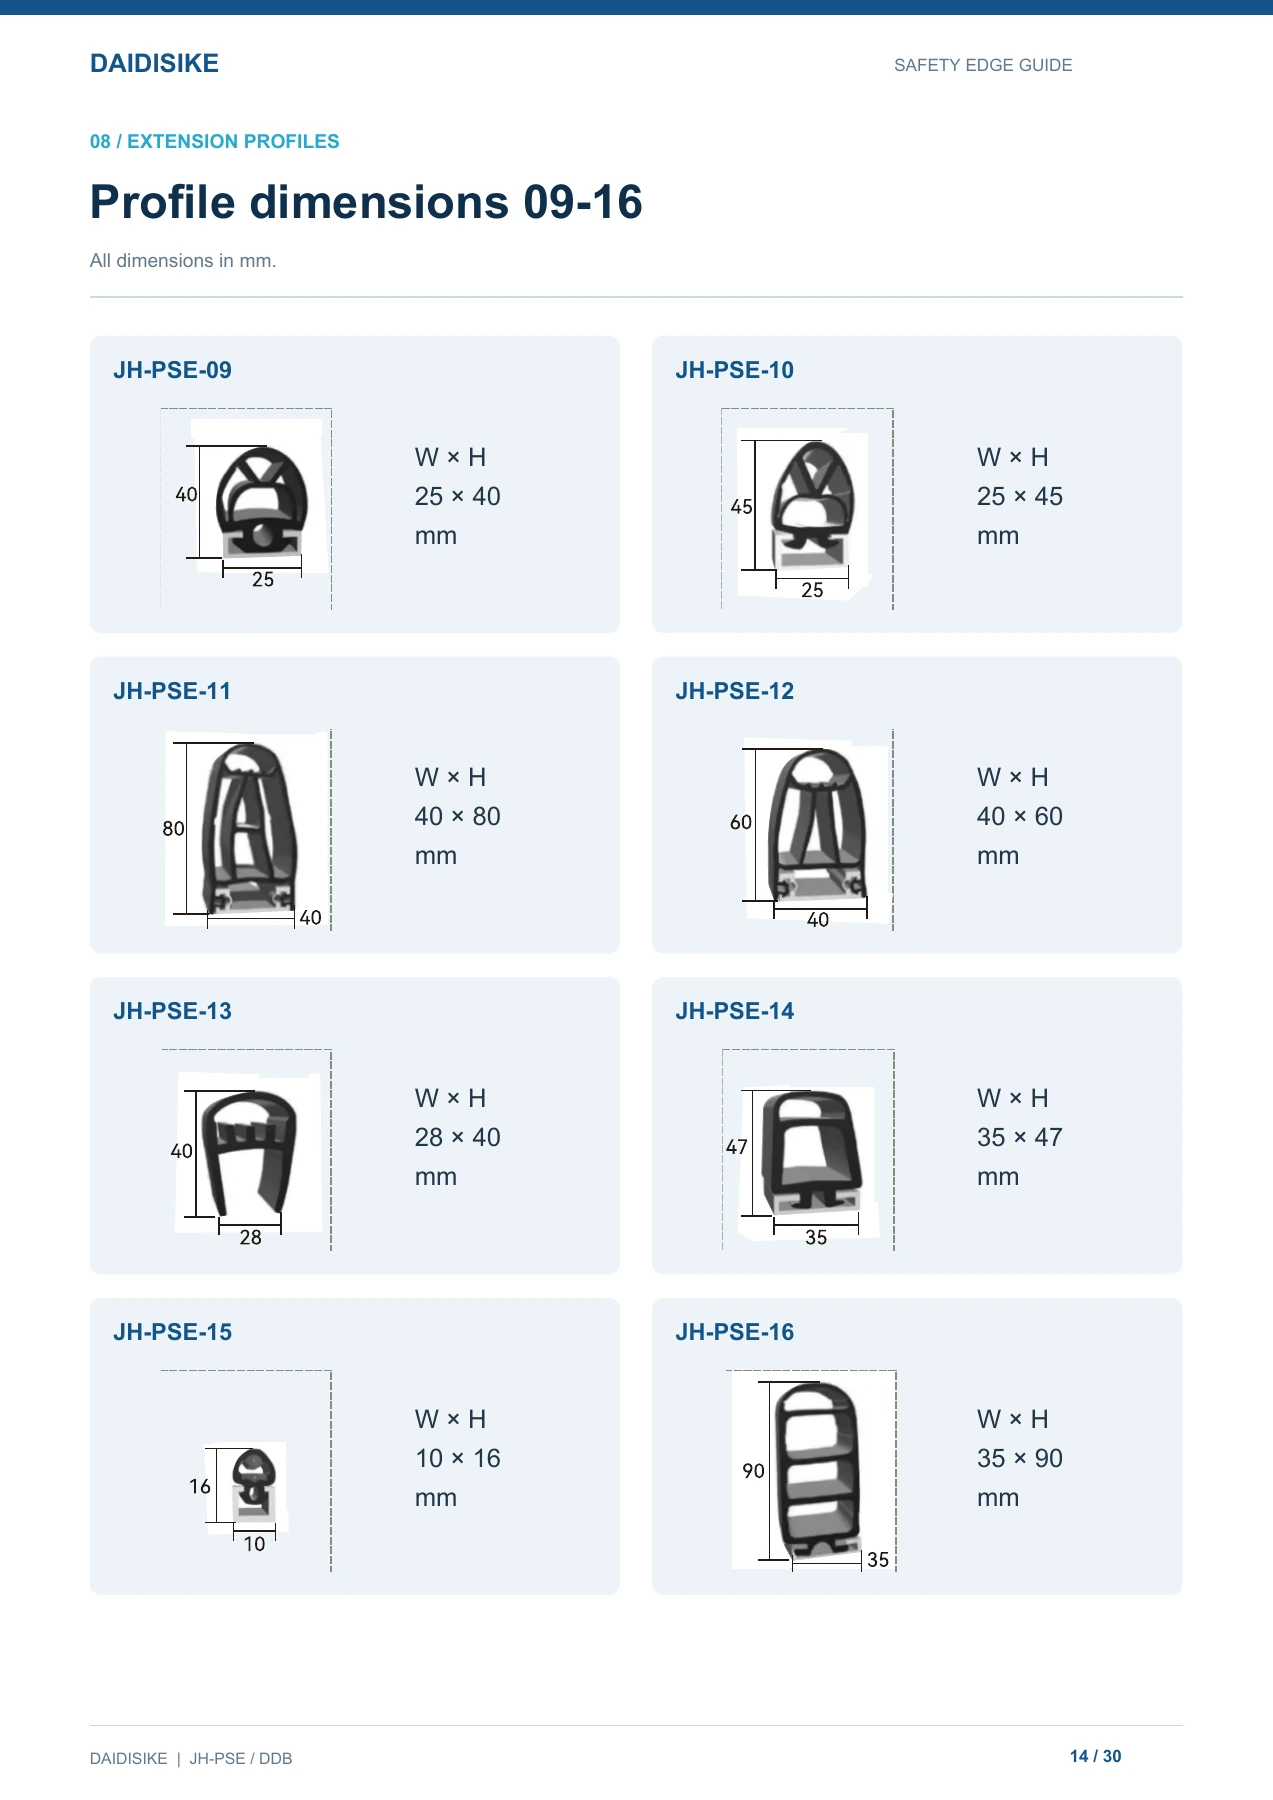
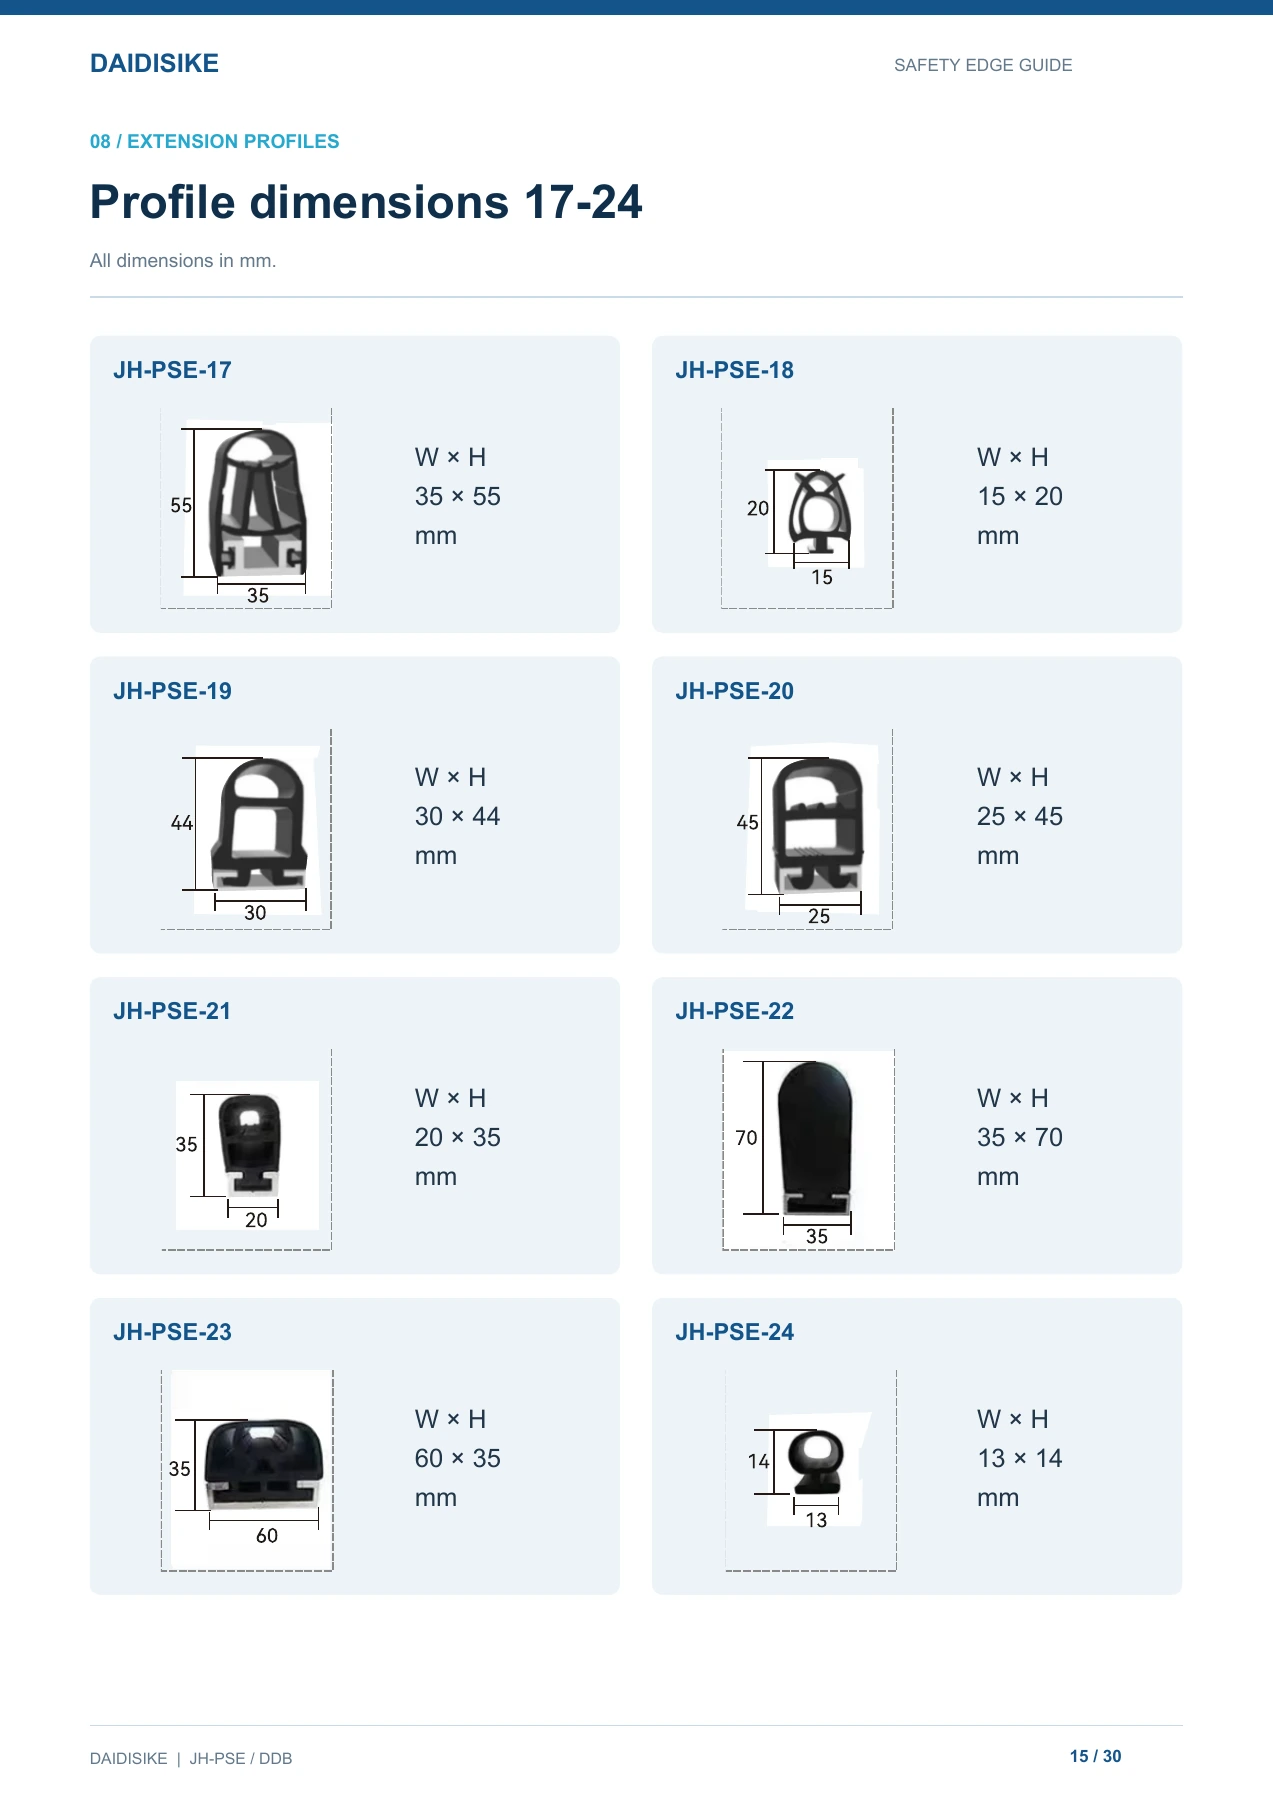
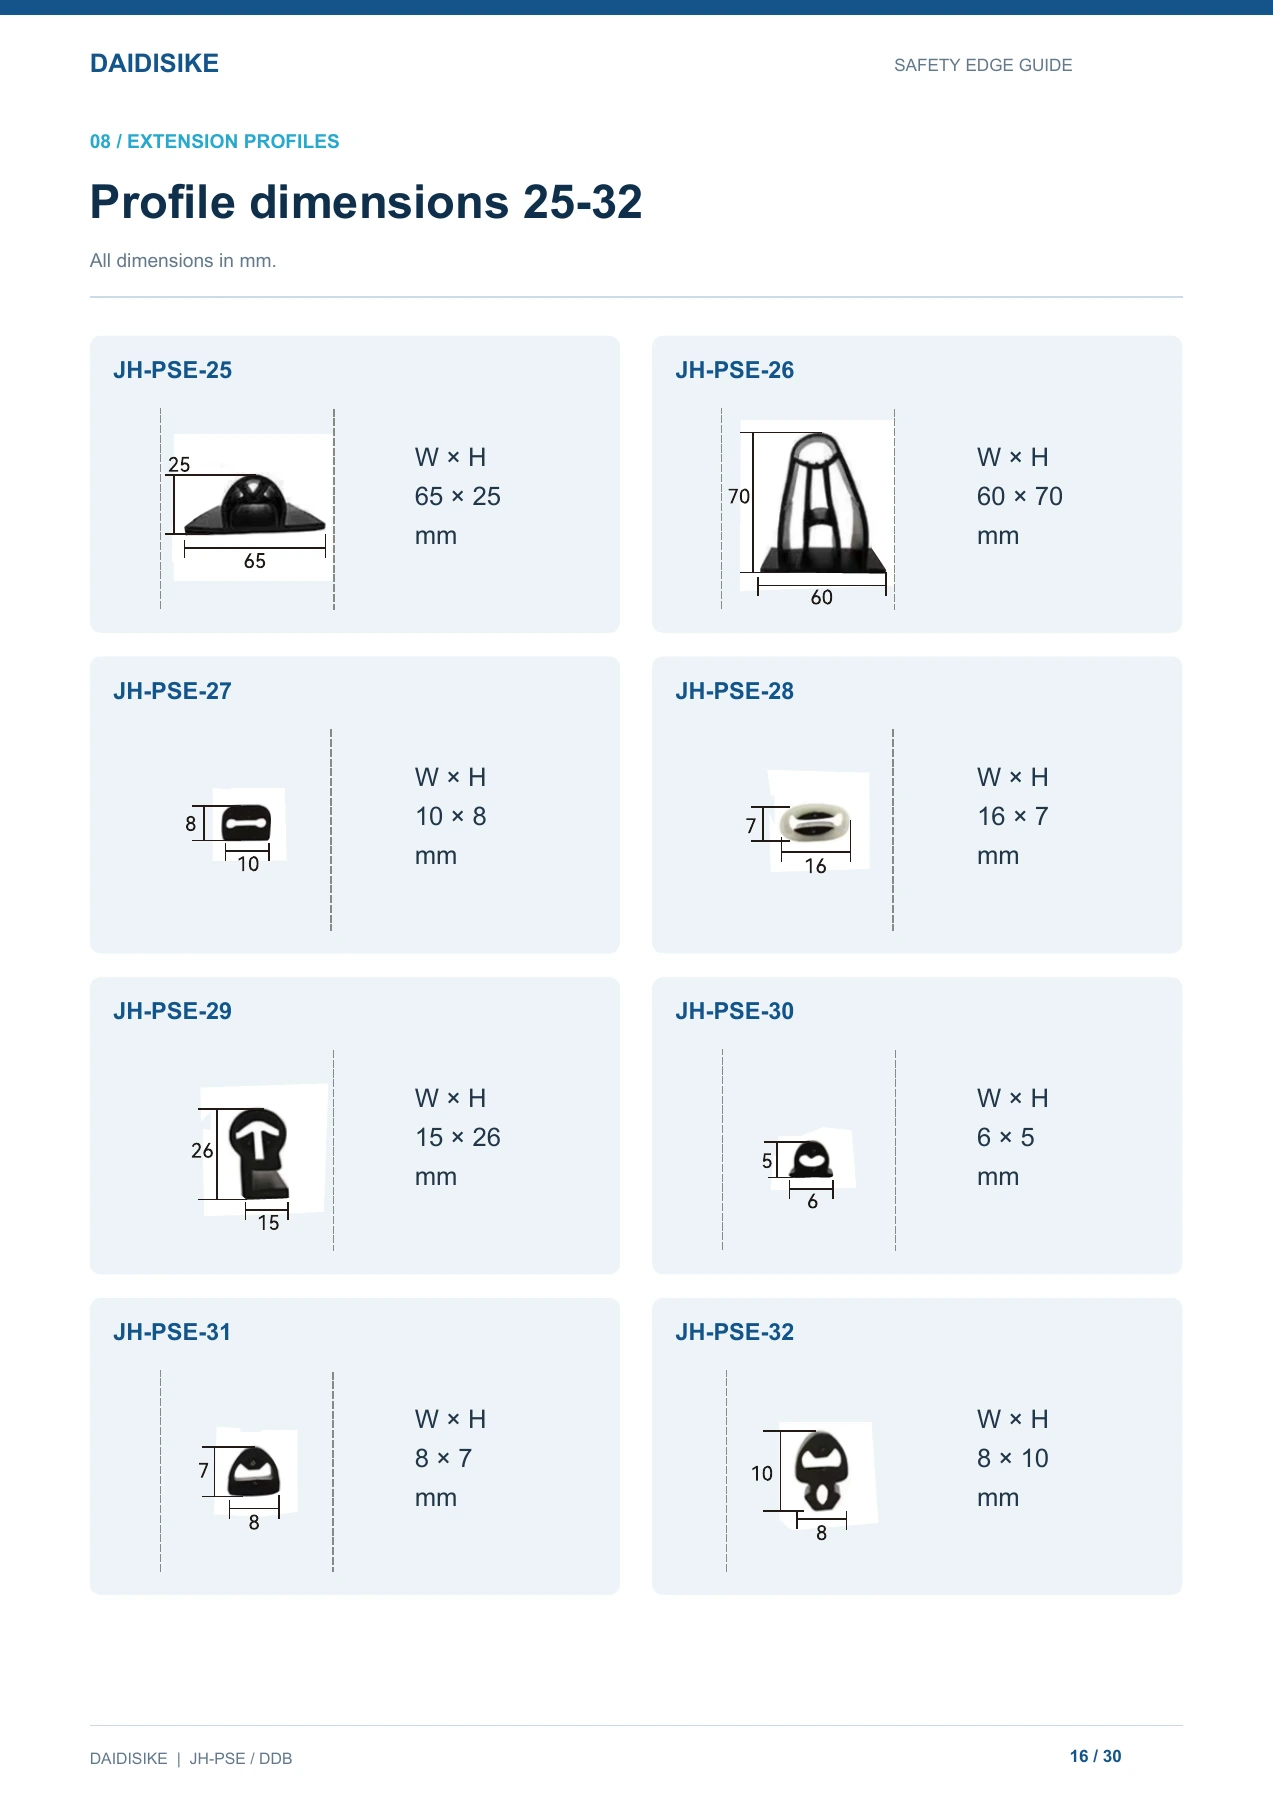
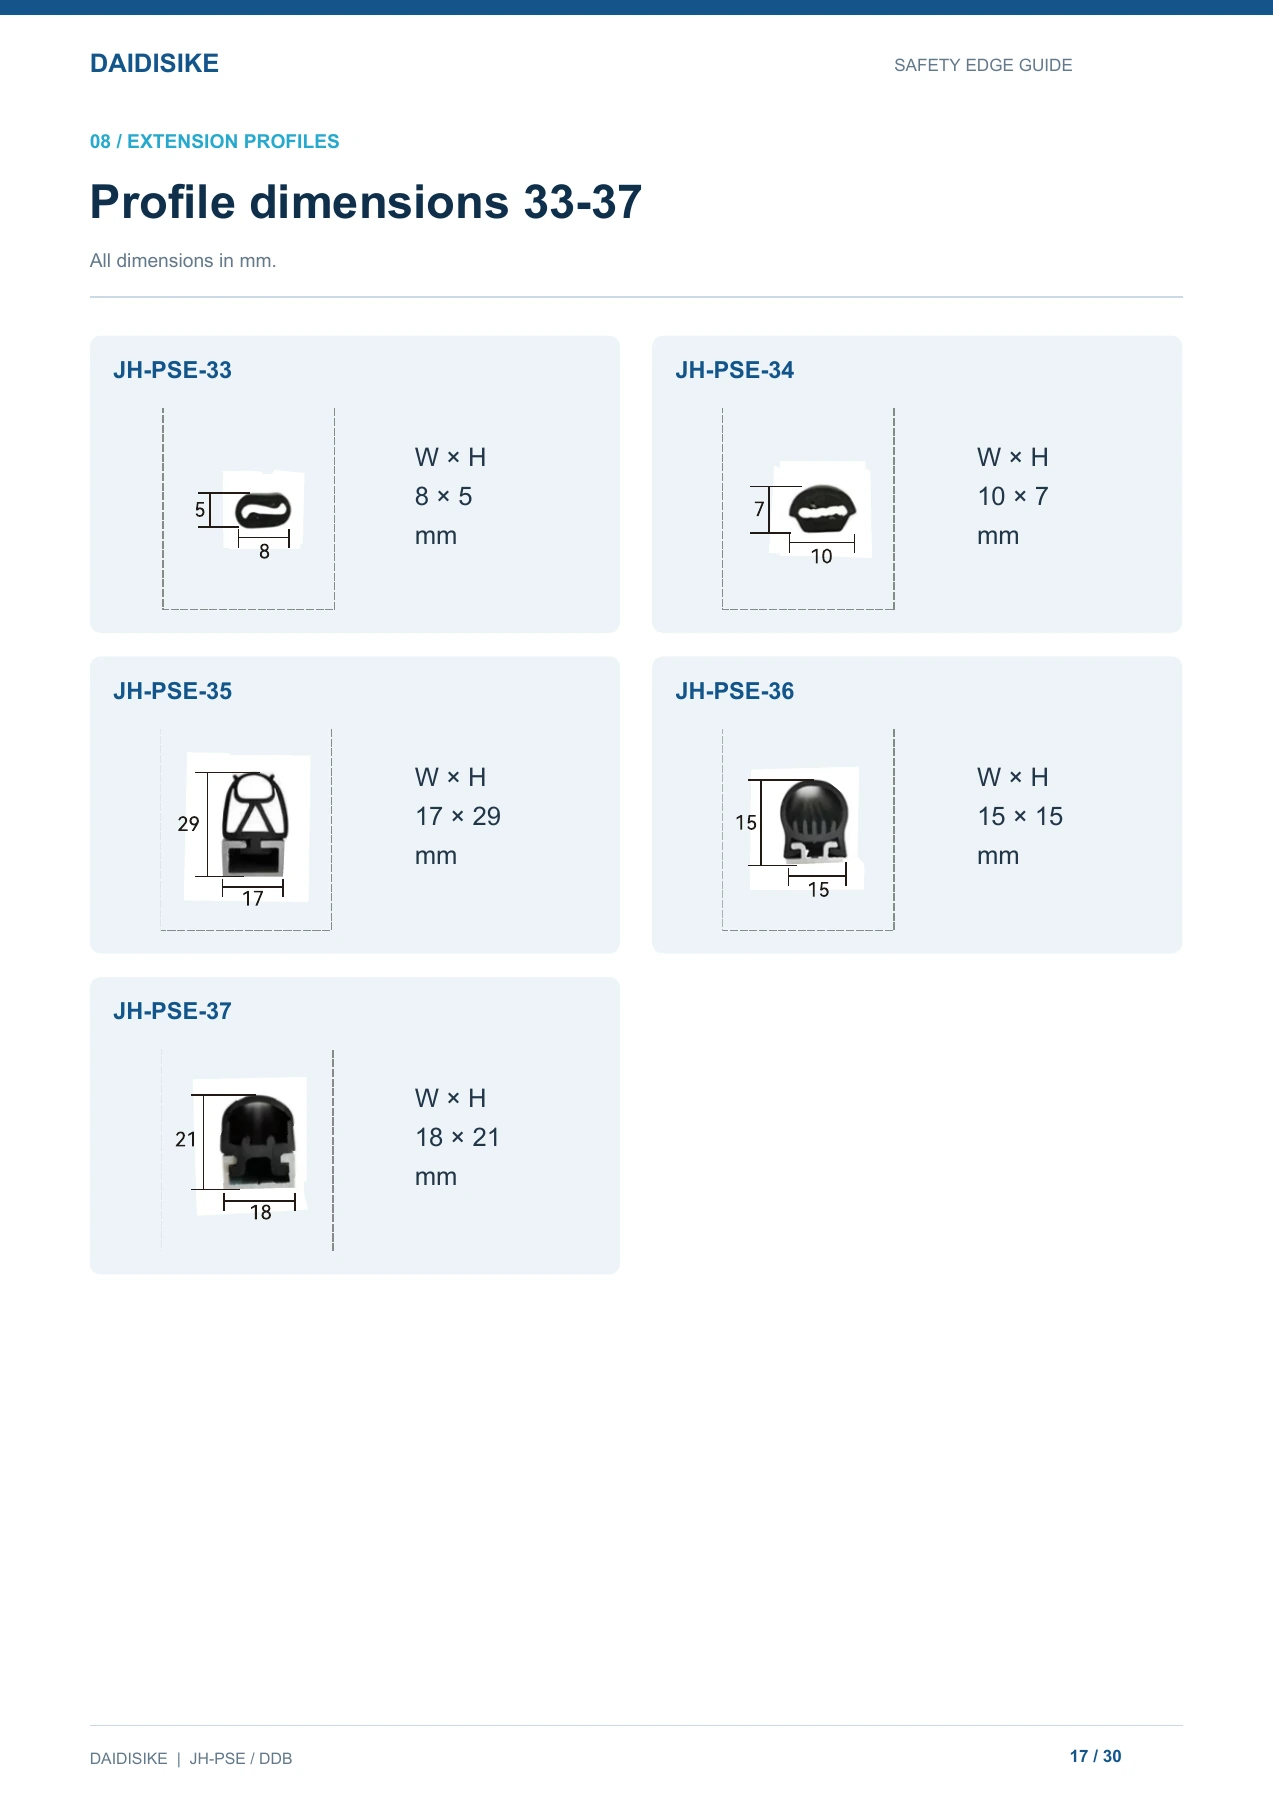
Profiles 01-37 broaden the choice of height, width and cross-section for straight, curved or shaped assemblies. Choose by the section drawing first; then check the model-specific actuation data and the minimum bend radius where one is provided.
| Item | Listed data |
|---|---|
| Material / color | Black EPDM |
| Length | 20-300 cm; custom options |
| Electrical limits | Voltage ≤24 V; current <1 A |
| Sensing logic | Normally open (NO); controller interface logic must be confirmed |
| Inactive ends | 20-30 mm at each end |
| Ambient temperature | -20 to +80°C |
| Standard cable | 50 cm long; outer diameter 3.5 mm; copper conductor 0.25 mm²; customizable |
Electrical limits are not a controller supply specification or permission to connect a load directly. Main-range 13 ms response, IP65, mechanical-life and overtravel figures are not specified for this extension table. Ask for the data relevant to your selected assembly.
| Model | Section W × H | Actuation travel | Actuation force | Bend radius |
|---|---|---|---|---|
| JH-PSE-01 | 30 × 50 | 3-5 | ≤30 | ≥120 |
| JH-PSE-02 | 25 × 40 | Not specified | Not specified | Not specified |
| JH-PSE-03 | 25 × 17 | 3-5 | ≤30 | ≥80 |
| JH-PSE-04 | 20 × 43 | Not specified | Not specified | Not specified |
| JH-PSE-05 | 25 × 30 | 3-5 | ≤30 | ≥120 |
| JH-PSE-06 | 26 × 27 | 3-5 | ≤30 | Not specified |
| JH-PSE-07 | 30 × 30 | 3-5 | ≤30 | ≥80 |
| JH-PSE-08 | 25 × 28 | 3-5 | ≤30 | ≥60 |
| JH-PSE-09 | 25 × 40 | 3-5 | ≤30 | ≥100 |
| JH-PSE-10 | 25 × 45 | 3-5 | ≤30 | ≥100 |
| JH-PSE-11 | 40 × 80 | 5-8 | ≤30 | ≥350 |
| JH-PSE-12 | 40 × 60 | 5-8 | ≤30 | ≥350 |
| JH-PSE-13 | 28 × 40 | Not specified | Not specified | Not specified |
| JH-PSE-14 | 35 × 47 | 3-5 | ≤30 | ≥120 |
| JH-PSE-15 | 10 × 16 | 3-5 | ≤30 | ≥55 |
| JH-PSE-16 | 35 × 90 | 3-5 | ≤30 | Not specified |
| JH-PSE-17 | 35 × 55 | 5-8 | ≤30 | ≥350 |
| JH-PSE-18 | 15 × 20 | Not specified | Not specified | Not specified |
| JH-PSE-19 | 30 × 44 | 3-5 | ≤30 | ≥60 |
| JH-PSE-20 | 25 × 45 | 3-5 | ≤30 | ≥100 |
| JH-PSE-21 | 20 × 35 | 3-5 | ≤30 | ≥100 |
| JH-PSE-22 | 35 × 70 | 5-8 | ≤30 | ≥200 |
| JH-PSE-23 | 60 × 35 | 3-5 | ≤30 | ≥150 |
| JH-PSE-24 | 13 × 14 | 3-4 | ≤30 | Not specified |
| JH-PSE-25 | 65 × 25 | 3-5 | ≤30 | ≥80 |
| JH-PSE-26 | 60 × 70 | Not specified | Not specified | Not specified |
| JH-PSE-27 | 10 × 8 | 2 | ≤30 | ≥60 |
| JH-PSE-28 | 16 × 7 | 2 | ≤30 | Not specified |
| JH-PSE-29 | 15 × 26 | 3-5 | ≤30 | Not specified |
| JH-PSE-30 | 6 × 5 | 2 | ≤30 | Not specified |
| JH-PSE-31 | 8 × 7 | 2 | ≤30 | Not specified |
| JH-PSE-32 | 8 × 10 | 2-3 | ≤30 | Not specified |
| JH-PSE-33 | 8 × 5 | 2-3 | ≤30 | Not specified |
| JH-PSE-34 | 10 × 7 | 2-3 | ≤30 | Not specified |
| JH-PSE-35 | 17 × 29 | 2-3 | ≤30 | ≥60 |
| JH-PSE-36 | 15 × 15 | Not specified | Not specified | Not specified |
| JH-PSE-37 | 18 × 21 | 3-5 | ≤30 | ≥150 |
“Not specified” preserves missing data in the guide; it does not mean zero, unlimited flexibility or the same value as a neighboring profile. Inactive end zones must be included when calculating usable coverage.
Pressure changes the sensing-contact state. A compatible controller interprets that change and, where supported by its approved circuit, monitors wiring faults. NO describes sensing logic; it does not by itself establish a complete fail-safe circuit.
R: two-core configuration with an integrated end resistor and one cable end. The guide lists 1.2 kΩ or 8.2 kΩ resistor options.
K: two- or four-core configuration without an end resistor; the connection layout shows signal cables at both ends. Confirm the delivered cable arrangement in the order drawing.
Main-range cable data: TPE jacket / VVR marking, 4 mm outer diameter, 2 × 0.35 mm² red/black conductors and 2 m cable length.
Use the supplied controller diagram for actual terminals, permitted edge quantity, resistor position, return path, supply and reset behavior. The guide's drawings are connection layouts, not a universal terminal-level wiring instruction.
Main-range 1.2 / 8.2 kΩ options, the extension 8.2 kΩ example and the separate DA31 5.6 kΩ example are not interchangeable. Confirm the edge and controller as a matched configuration. An ordinary PLC input or a similarly named relay is not proof of a suitable safety interface.
JH-PSE-108-30-RS-CRead profile, length, electrical configuration, shape and base by their field positions. The electrical R means “with resistor”; the shape field uses R / S for standard / special. The guide also gives extension example JH-PSE-01-20-2KS. Confirm the complete code and drawing before purchase.
The following illustrations explain possible contact-detection locations. They are conceptual application visuals, not photographs of the ordered models or validated installation drawings.
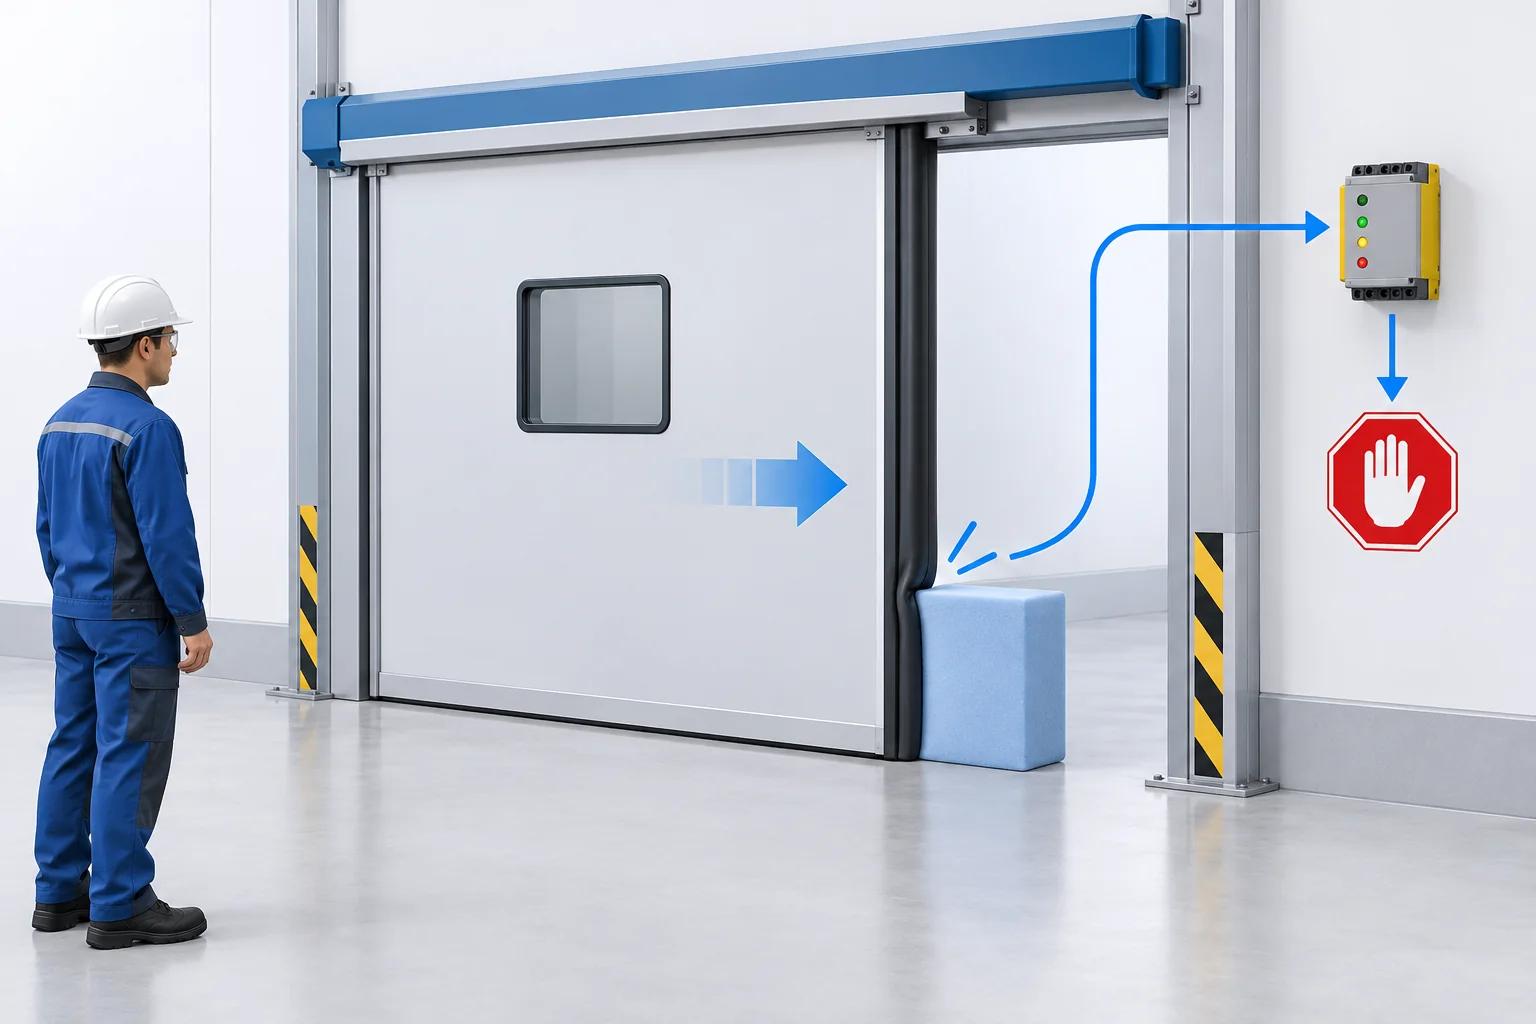
Place contact sensing along the hazardous closing boundary. Check hinges, overlaps, joints and inactive ends. The risk assessment must determine whether stopping, safe reversing or additional protective measures are required.
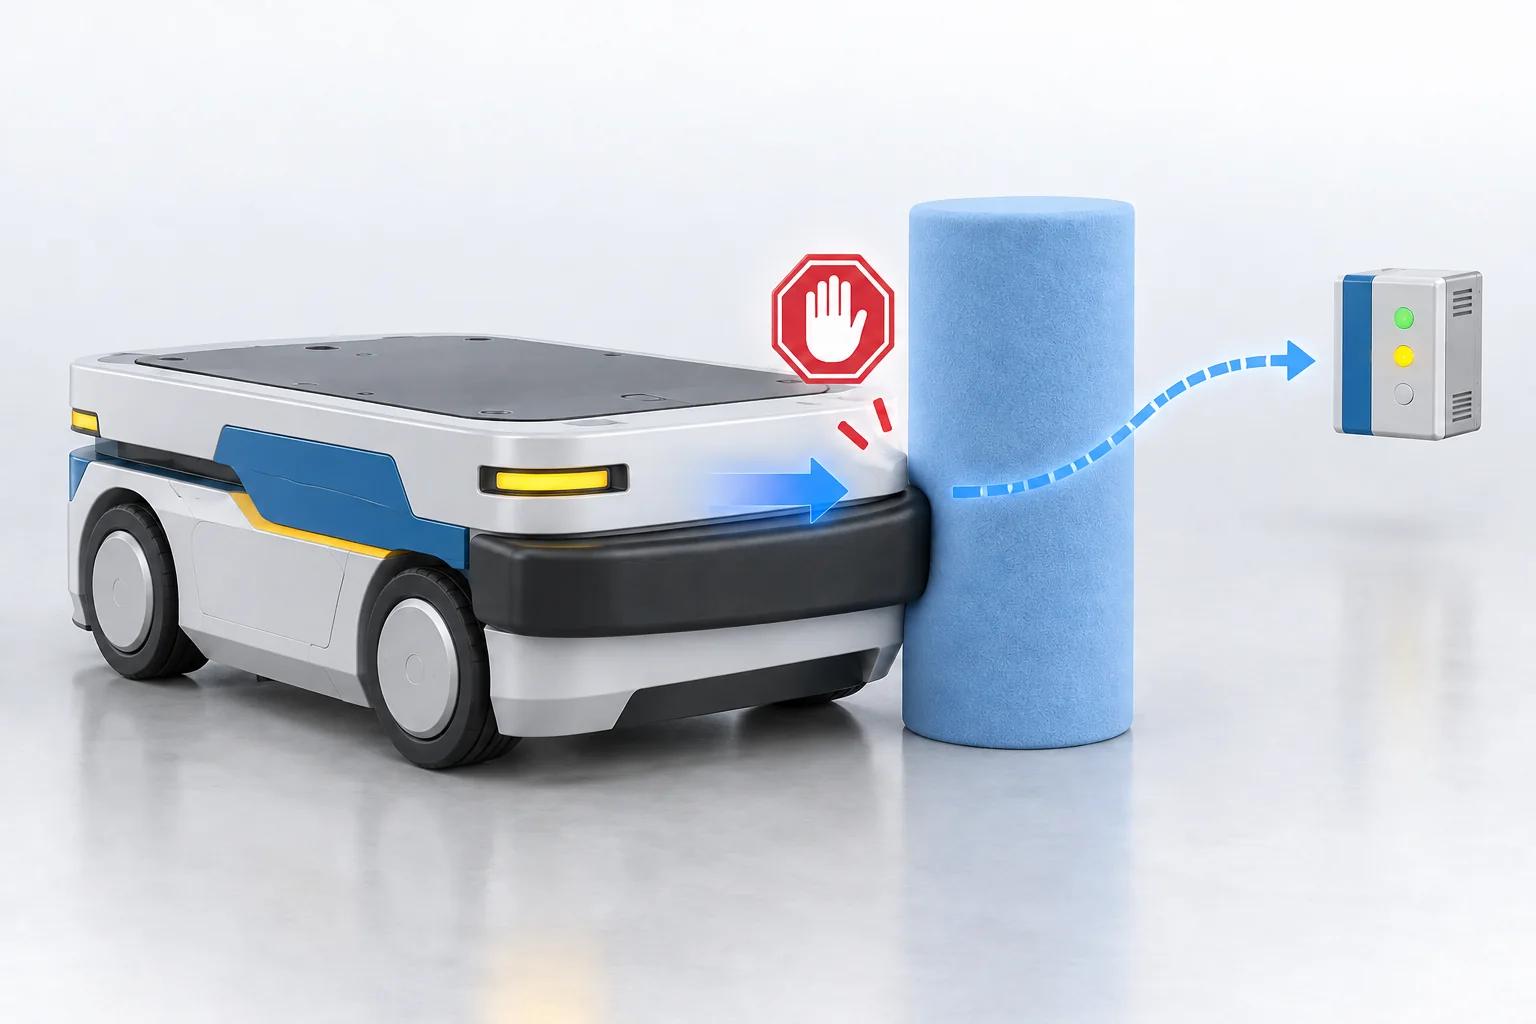
Follow the vehicle contact perimeter with a suitable profile. Validate maximum speed and load, actual braking performance, contact direction and remaining compression; an attractive bumper shape does not prove adequate protection.
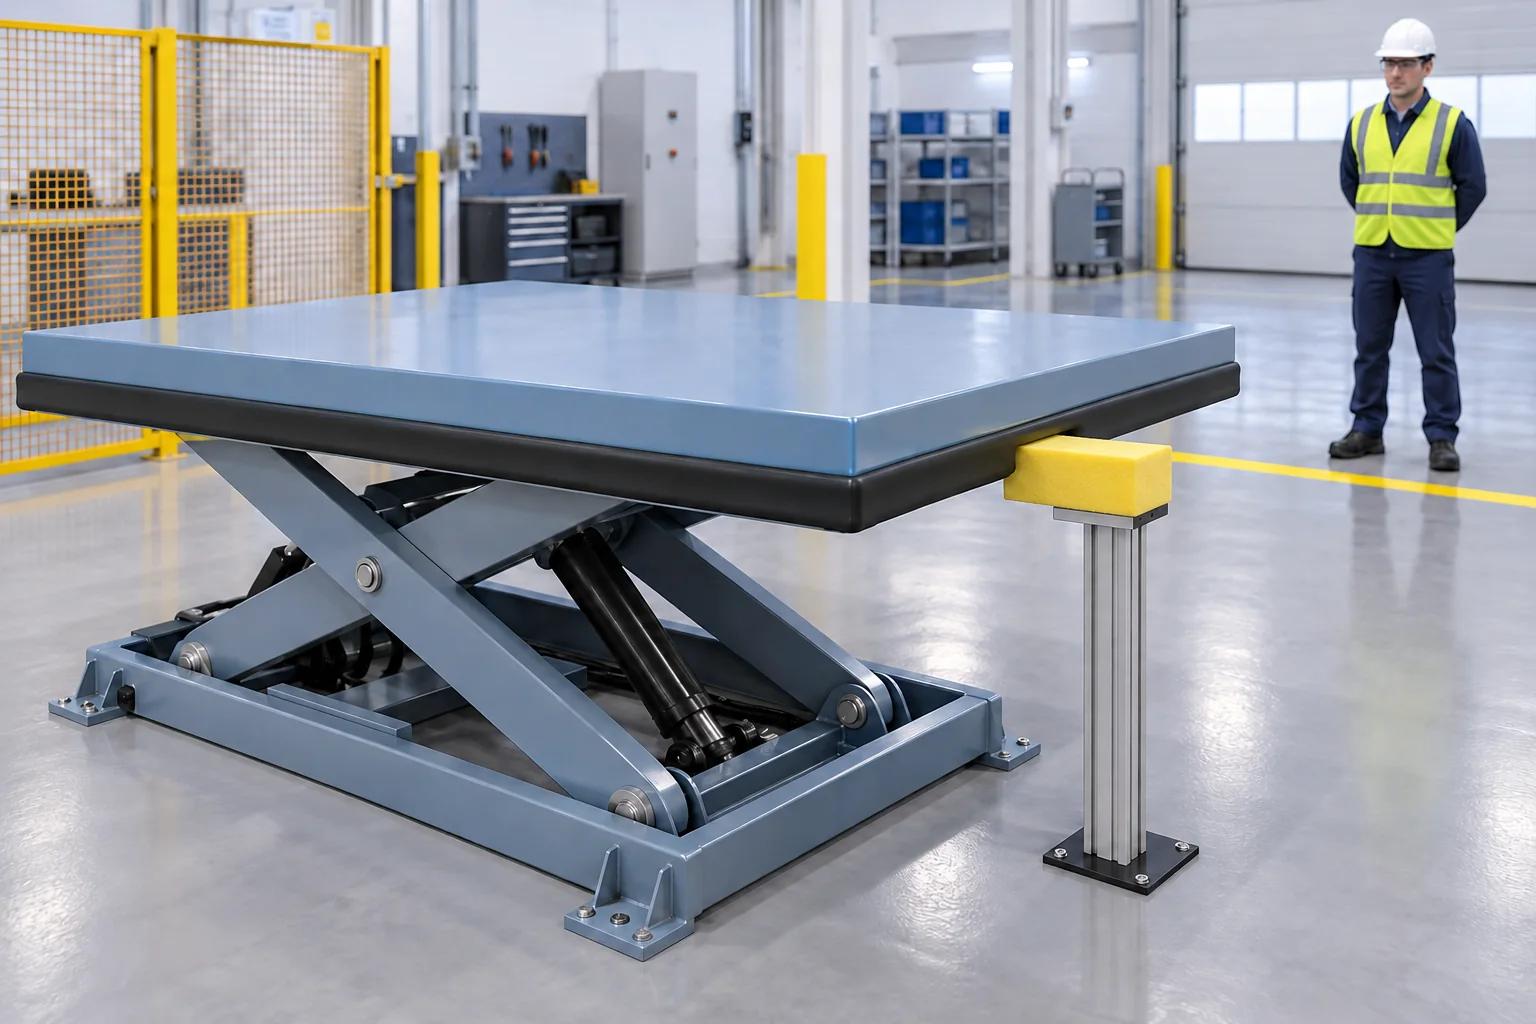
Address accessible contact edges on moving covers and lifting equipment. Check low contact points and bypassable gaps, and provide the required guarding. Never enter beneath an unprotected lifting mechanism.
Use suitable test tools or foam objects, not fingers or body parts exposed to crushing. Contact protection may need to work alongside guards, interlocks or non-contact detection.
Qualified personnel must work to the approved machine and controller drawings. Isolate power before wiring, and do not cut open a delivered sealed edge.
An always-active signal can indicate preload, damage, a short circuit or an incorrect resistor. No actuation can indicate an inactive zone, unsuitable force direction, an open circuit or an input mismatch. Intermittent faults require checks of flexing cables, joints, sealing, mounting and vibration. Never bridge a safety input to keep a machine running.
30-page English guide. JH-PSE main range: pages 7-11; extension range: pages 12-19. Includes both JH-PSE and DDB/DDBT series, installation and commissioning guidance. Preview opens the original PDF in a new tab; download saves the same document. Use the approved order-specific drawing and controller instructions for installation.
Shared 30-page English catalogue for JH-PSE profiles and DDB / DDBT assemblies. Match each table and drawing to the exact series; confirm the supplied edge and evaluation controller before installation.
Confirm the document and CAD file match your exact ordered version before installation or mechanical design. Contact us if your model is not listed.
For a useful quotation, include the mechanical drawing and the controller details, not just “a safety edge.” This allows the profile, sensing coverage and electrical configuration to be checked together.
| Project detail | What to provide |
|---|---|
| Product / profile | JH-PSE main or extension model; the required section drawing |
| Dimensions and coverage | Overall length, active coverage, inactive ends, mounting space, curve radius and corner positions |
| Motion and contact | Hazardous edge, actuation direction, maximum speed / load and post-actuation travel |
| Electrical interface | Controller model and diagram; cores, cable ends, resistor / power, output functions and connector |
| Installation and environment | Base or adhesive mounting, fasteners, seals, cable support and environmental conditions |
| Required documents | Approved assembly drawing, order-specific wiring diagram, inspection information and operating instructions |
The main range contains profiles 108, 110, 215, 230, 245, 345 and 360, with model-specific actuation and overtravel data, a listed 13 ms response and IP65 protection. The extension range contains profiles 01-37, with its own dimensions, actuation table, black EPDM material and -20 to +80°C ambient range. Main-range response, ingress protection and overtravel figures must not be assumed for the extension profiles.
Not automatically. Profiles 108, 110 and 215 have a listed overtravel value of 0 in the guide. The other main profiles have model-specific less-than overtravel figures; these are not guaranteed minimum available compression. Obtain the selected profile data and validate the stopping reserve for the actual machine, load, speed and contact direction.
NO means normally open sensing: pressure changes the contact state. In the electrical configuration field, R denotes a two-core configuration with an end resistor, while K denotes a two- or four-core configuration without an end resistor. R and S in a separate shape field mean standard and special shape. Read the full code by field position rather than interpreting every R as the same option.
No. The main range lists 1.2 kΩ or 8.2 kΩ R-type end resistors; the extension connection example lists an 8.2 kΩ, 0.25 W resistor. The DA31 example elsewhere in the guide uses 5.6 kΩ and must not be treated as universal compatibility. Confirm the exact input circuit, resistor, cable arrangement and approved wiring diagram before connection.
No. Contact changes the sensing state; a compatible controller and the machine stopping system must then respond. Controller delay, switching time, inertia, speed and load contribute to the motion after actuation. Measure the complete machine stopping performance and verify that the selected profile provides sufficient usable compression and an appropriate safety margin.
Do not cut open a sealed edge. Order the required length, contour, cable exits and sealed ends. Multiple-edge connections must follow the supplied controller-approved drawing, including termination, return conductors and permitted edge quantity. A parallel NO-contact arrangement does not by itself prove that every branch is monitored for an open circuit.
Send the full model or required section drawing, overall length, protected contour, force direction, mounting space, speed and load, measured or expected stopping travel, cable exits and connector requirements. Identify the controller and its required resistor and input arrangement. Request an order-specific drawing, wiring diagram, inspection information and operating instructions.
Product data and source drawings: the DAIDISIKE 30-page English JH-PSE / DDB safety edge guide. Figures remain range- and model-specific. Confirm the current ordered assembly, electrical compatibility and complete safety function with qualified personnel. No third-party certification or achieved machine safety level is implied by this product overview.